Physical AI · Sensor-Recorded Training Data
Verified demonstration data.
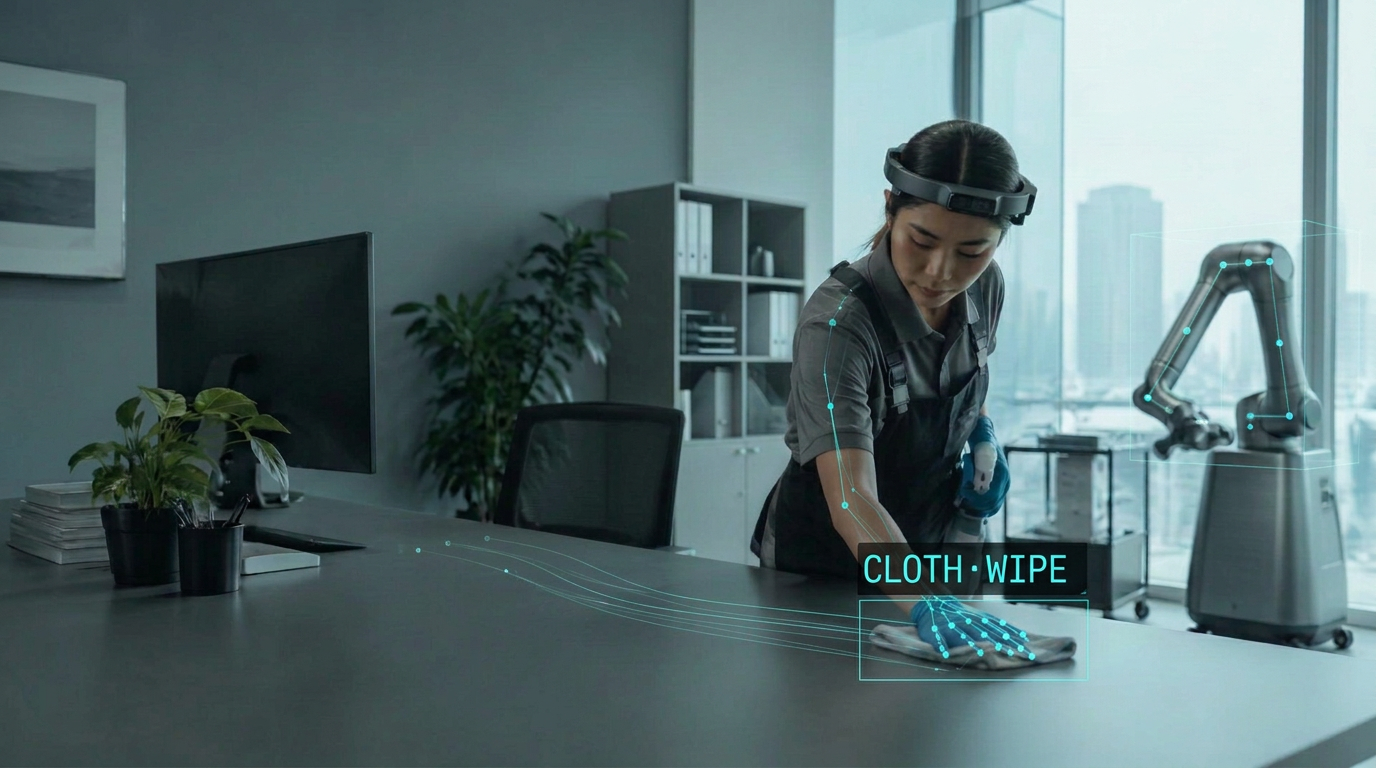
Synchronized ego-vision & kinematics
Egocentric video, hand poses, action labels and sensor streams on a shared timeline.
Real-world operational workflows
Long-horizon tasks recorded in operational commercial facilities by trained staff.
Policy-ready formats
Annotated datasets for robot foundation models, exportable to common formats such as RLDS and LeRobot.
11
data components
10–50h
pilot scope
1,000+h
expansion capacity
8+
target industries
Structured action demonstration
Segmented action sequences
t+00.0s
Approach workspace
t+03.0s
Identify surface
t+06.0s
Pick up cloth
t+09.0s
Pick up spray
t+12.0s
Apply spray
t+15.0s
Wipe surface
t+18.0s
Reposition cloth
t+21.0s
Inspect surface
t+24.0s
Correct missed area
t+27.0s
Return tools
t+30.0s
Final state check
Data provenance & ecological validity
Own operations
Recordings come from our own cleaning company. No intermediaries, no staged scenes.
Adjustable processes
Tasks, sequences, tools and environments can be adapted to your specification.
Structured output
Segmented actions, object labels, success and failure states.
Defined scaling
From a pilot of 10–50 hours to recurring collection.
Next step
Technical discovery call
Define target tasks, schema and delivery format for your pilot.